13468378666 7×24-hour service hotline
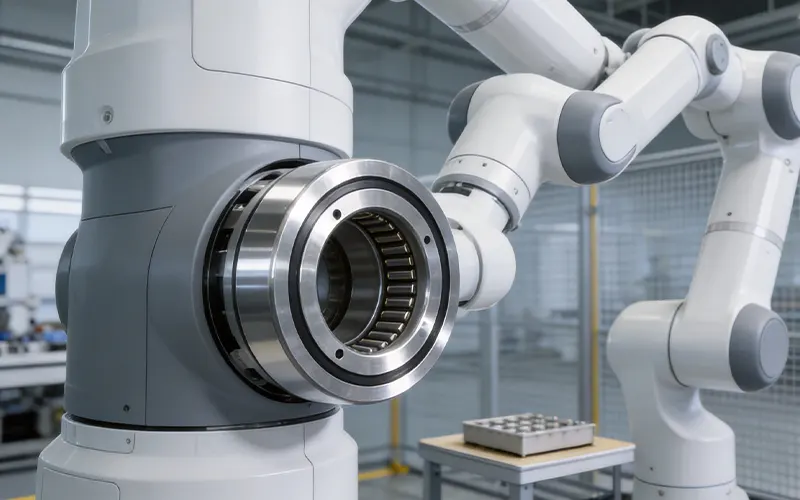
Collaborative robots are a new type of robot that can collaborate with humans in a common workspace, widely used in precision assembly, inspection, packaging, medical assistance, and other scenarios. Collaborative robots have extremely high requirements for safety, lightweight, and precision. Their joint parts require high rigidity, low inertia, and high-precision bearing support to ensure safety and operational accuracy during human-machine collaboration.
The joint parts of collaborative robots usually adopt integrated design, with extremely strict requirements for the volume and weight of bearings. The thin-walled cross roller bearing CRBH series produced by Shandong Hangmu Precision Bearing Manufacturing Co., Ltd. has the characteristics of compact structure, light weight, high precision, and strong rigidity. It is suitable for the joint parts of collaborative robots and can effectively reduce joint volume and overall weight, helping collaborative robots achieve the design goals of lightweight, high-precision, and high safety.
The precision level of the company's products can reach P2, P4, P5, which can meet the strict requirements of collaborative robots for bearing accuracy and reliability, providing reliable guarantee for the stable operation of collaborative robots in precision assembly, medical assistance and other scenarios.
Previous: Robotic arm
Next: Parallel robot
HOMVIP specializes in the research and manufacturing of precision cross roller bearings, equal section thin-walled bearings, and harmonic reducer bearings. Our products are exported to more than 50 countries and regions worldwide.
Learn more >
All rights reserved. © 2026 Shandong Hangmu Precision Manufacturing Co., Ltd|
Technical Support:Shandong Hangmu Precision Manufacturing Co., Ltd|Sitemap